MJCF · Unitree · BSD 3-Clause · 12 MB
Unitree Go1
Go1 Quadruped Robot developed by Unitree Robotics. It is derived from the publicly available URDF description.
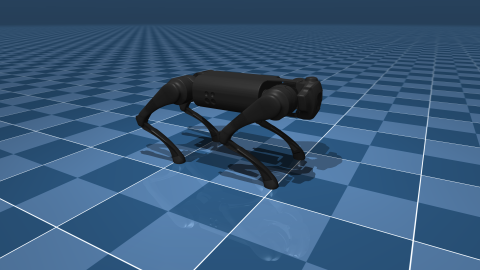
The first time takes a moment
Opening this model fetches it from the Menagerie repository — the description and the meshes it references, about 12 MB — and keeps it here, so anyone opening it after you gets it straight away. Nothing of yours is uploaded in the process: the simulation itself runs in your tab, on MuJoCo compiled to WebAssembly.
What you can do with it here
- Simulate it under gravity and contact, write a controller in JavaScript, shove it with the mouse, and run the four repeatable tests that answer with a number rather than an impression.
- Look inside it: the kinematic tree, every joint and its range, collision geometry against the visual mesh, where the mass actually sits.
- Convert it to URDF for ROS, or to USD for Isaac Sim — each direction states what it could not carry across.
-
Download it as a folder —
the description, the meshes under
meshes/, the licence and a note saying where it came from. Mesh paths are rewritten to point inside the folder, so it opens outside a ROS workspace as well as inside one. -
Download it as USD for
Isaac Sim — one
.usdawith the meshes written inside it, as described on OpenUSD for robots. - Download it as a 3D model — one GLB with every part of the Unitree Go1 in place and named as its description names it, for Blender, a render or a web page; or as an STL in millimetres to print. Both are written in your browser, with the licence inside the GLB.
- Author a movement for it and check the motors it declares can actually perform what you drew.
- Edit it as URDF — change a joint range, a mass or a shape in a form or in the text, with its meshes brought along, and save the result as your own copy.
Whose model this is
The Unitree Go1 model is BSD 3-Clause licensed and was published by Unitree as part of the MuJoCo Menagerie, curated by Google DeepMind. This page is a way to open it, not a claim on it — the folder upstream carries the licence text, the changelog and the README its authors wrote:
https://github.com/google-deepmind/mujoco_menagerie/tree/main/unitree_go1
If you use the model in your own work, credit that folder rather than this page. If it has changed upstream since we fetched it, the copy here is the one you get — say so in a bug report and it will be re-fetched.
Nearby in the catalogue
- ANYmal B — ANYbotics, BSD 3-Clause
- ANYmal C — ANYbotics, BSD 3-Clause
- Boston Dynamics Spot — Boston Dynamics, BSD 3-Clause
- Google Barkour v0 — Google, Apache 2.0
- Google Barkour vB — Google, Apache 2.0
- Unitree A1 — Unitree, BSD 3-Clause
- Unitree Go2 — Unitree, BSD 3-Clause
- ANYmal D — ANYbotics, BSD-3-Clause
All the models · every Unitree robot, with what each description says